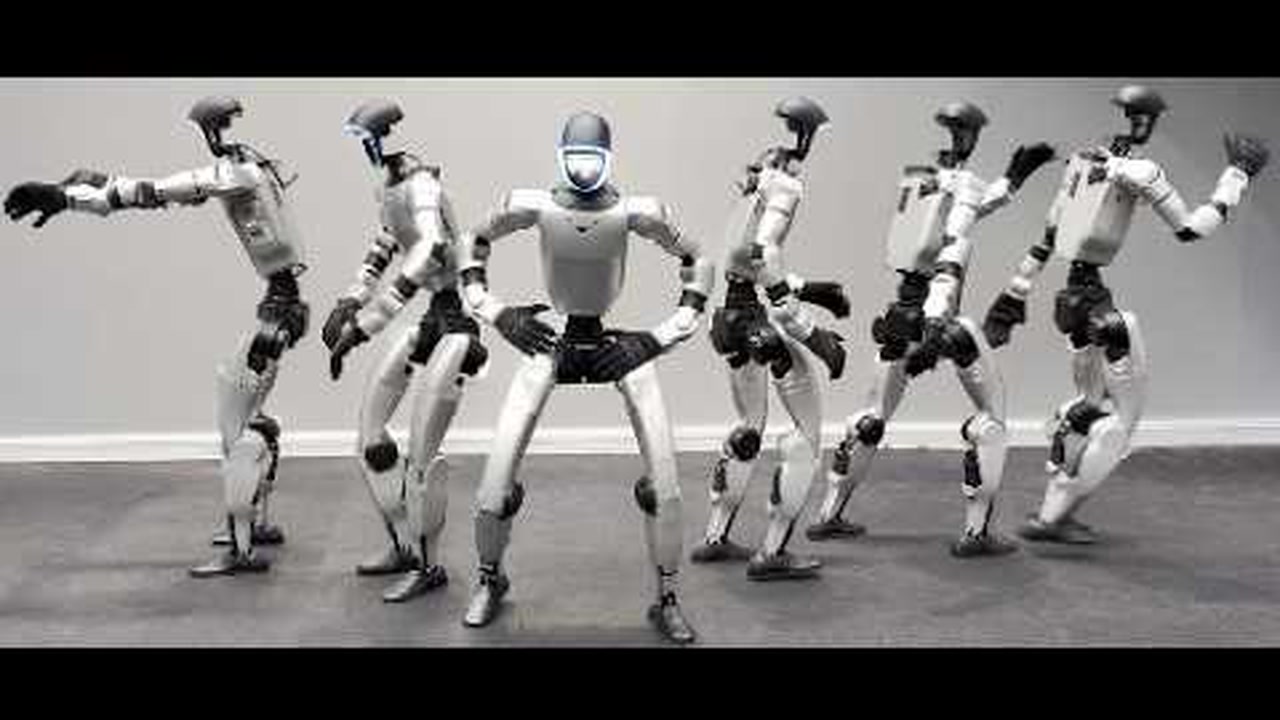
Disney Research demonstrated a robot controller that can change walking style in real time while separately following a user’s direction and speed commands.
The system, called Walk Like This, takes two inputs: a short reference clip for the desired style and a joystick command for velocity. A diffusion model creates the motion target, and a reinforcement-learning controller tracks it on the robot.
The training method uses a large collection of motion data without requiring a style label for every example. The controller can also apply styles it did not see during training, according to the project abstract.
The demonstration moves from a simulated humanoid to a physical robot. Its gait changes continuously as the style reference changes, while the joystick continues to control where and how quickly it moves.
Sources: Disney Research’s Walk Like This project page and official video.